Complete welding systems designed around your workpiece and process. Robots, fixtures, positioners and programming work together as one integrated system.
Metal structures, frames and pipework
Aluminium and stainless steel welding
TALOS.EasyPath integration for seam tracking
Engineering, installation, training and support
WELDING / FIXED TABLE
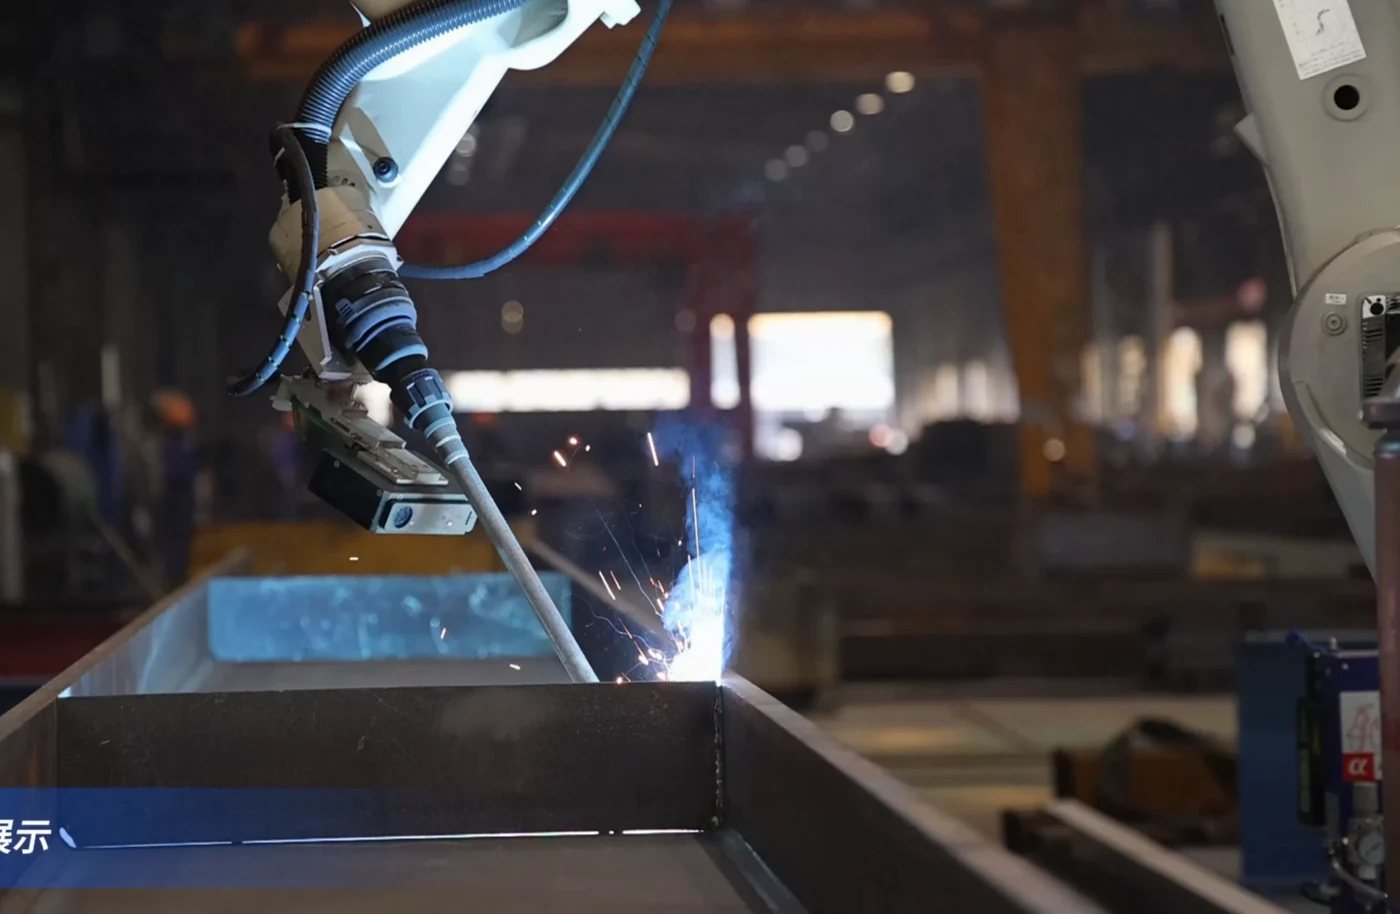
Fixed-table welding cell
The fixed table forms the basis of the cell. Robot reach, fixtures and seam access are engineered around the actual workpiece. Delivery covers system integration, installation and training.
Layout
Robot + worktable
Workpieces
Frames / fabrications
Configuration
Application-specific
Equipment & configuration
Robot, controller and welding equipment
Worktable and application fixtures
Operator access and protection design
Programming and trials on the workpiece
Final configuration is determined by the workpiece dimensions, mass, material and weld sequence.
WELDING / POSITIONER
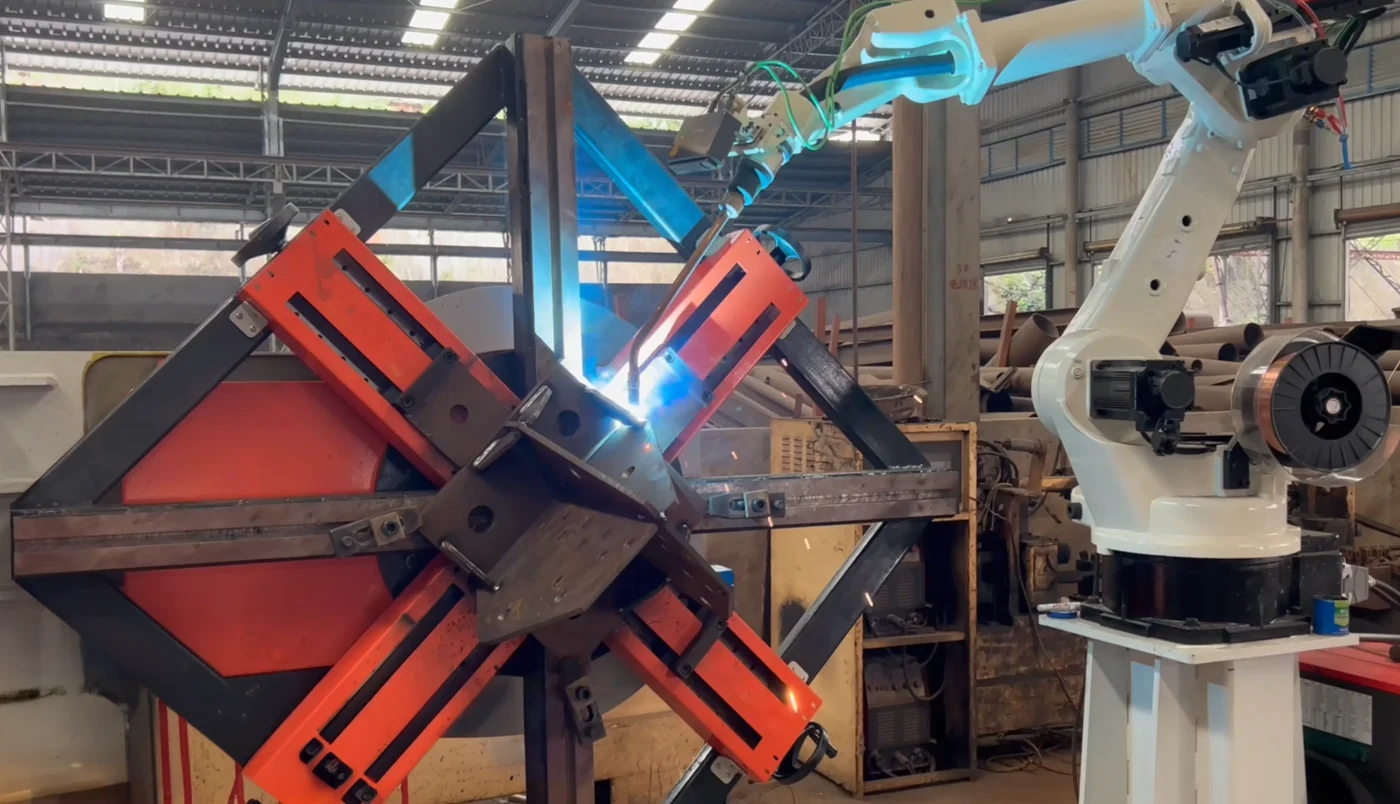
Positioner welding cell
The positioner orients the workpiece to provide torch access to the required weld locations. Payload, centre of gravity and required orientation are considered together with robot placement and fixturing.
Layout
Robot + positioner
Access
Multiple faces
Tooling
Dedicated fixtures
Equipment & configuration
Robotic arm and welding system
Positioner selected for the workpiece
Fixturing and seam accessibility
EasyPath integration assessed for the application
Load, torque and rotation envelope are determined during system engineering.
WELDING / LINEAR AXIS
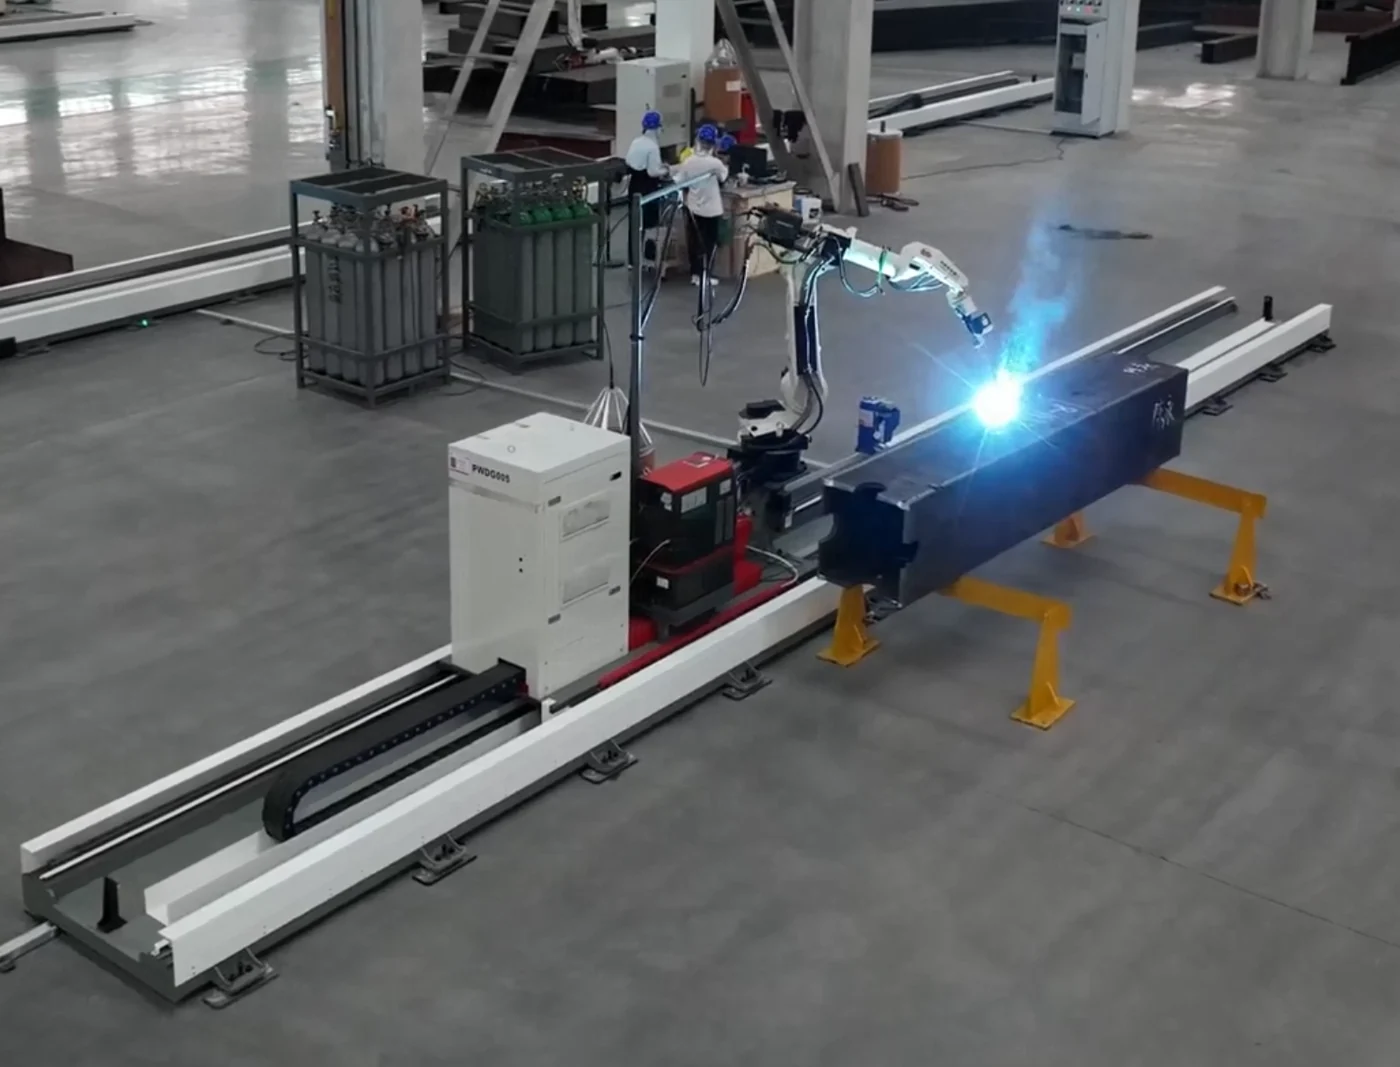
Robot on a linear axis
The linear axis moves the robot base along the installation. Layout planning combines axis travel, arm reach, workpiece access and loading positions.
Layout
Robot + linear axis
Application
Long workpieces
Travel
Layout-dependent
Equipment & configuration
Robot mounted on a linear travel system
Workstations for large parts
Integrated operation and welding equipment
Path creation method selected for the application
Axis travel and the number of stations follow from workpiece geometry and available floor space.
04ENGINEERING APPROACH
APPLICATION → SYSTEM → VALIDATION
Engineering criteria for system configuration.
Robot selection is one part of the study. Performance comes from the combination of process, mechanical layout and production flow.
ENGINEERING / 01
Workpiece & process
Material, thickness, joint geometry, assembly tolerances and target quality define the starting point for engineering.
ENGINEERING / 02
Reach & fixturing
We assess torch access, part positioning and motion space, selecting a table, positioner or linear axis for the application.
ENGINEERING / 03
Cycle & production flow
The total cycle includes loading, travel, processing and unloading. Palletizing also requires gripper, pattern and pallet-exchange assessment.
ENGINEERING / 04
Controls & handover
Electrical design, equipment interfaces, functional checks, training and technical support complete the installation.
Path generation and seam tracking
PROGRAMMING / SCANNING / TRACKING
Technology
Conventional robotics
No Programming Welding
TALOS.EasyPath
How the path is defined
Teaching / programming
Scanning and seam selection
Tracking the actual seam
When it is used
Robot job preparation
Workpiece job creation
During welding execution
What it addresses
Repeatable geometry
Frequent changes / small batches
Seam position and geometry variations
Technology selection and combination are assessed for the application, robot controller and workpiece geometry.
Application engineering assessment
Describe the workpiece, required cycle time and available installation space.